Yufeng Li 李雨峰

Ph.D. Student @ Shanghai Jiao Tong University · Jointly trained at Beijing Zhongguancun College

I am a Ph.D. student at Shanghai Jiao Tong University, advised by Prof. Junchi Yan. I am also jointly trained at Beijing Zhongguancun College, advised by Researcher Kai Chen.

My research focuses on embodied intelligence for precise and safety-critical robotic systems. I am interested in scientific robotics, dexterous manipulation, automated chemistry laboratories, vision-language-action models, safe reinforcement learning, optimal transport, generative policy learning, and AI for science.

Recent projects study how robots can operate in chemical-laboratory environments, how VLA models can specialize task-relevant action factors, how evidence-constrained agents can plan inorganic-material synthesis, and how optimal-flow views can support safer reinforcement learning.

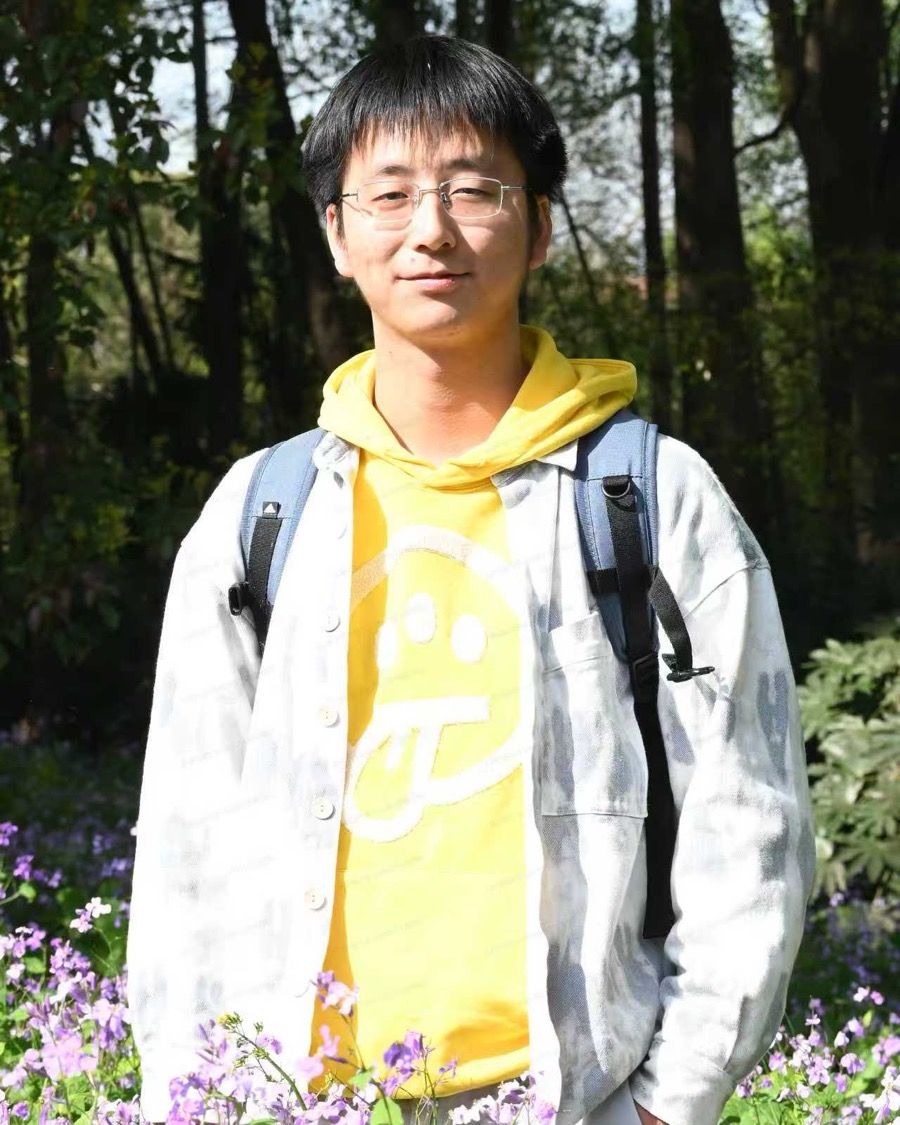
Portrait of Yufeng Li

Updates

[Sep. 24, 2026] Remembering What Matters, NeurIPS 2026.
[Sep. 2026] SAGE-Mat (GOAI) - Finalist, 8th place in the Frontiers Exploration track of the World AI Open Source Competition.
[Aug. 2026] SynMatAI AI4S Future ScienceSkills Hackathon - Champion (1st of 82 teams).
[Jun. 2026] SafeLab, ICML 2026.
[May 2026] GuidedVLA, RSS 2026.
[Apr. 2025] Optimal Flow Transport and its Entropic Regularization, ICLR 2025.
[Oct. 2024] REFRAME, ECCV 2024.

Selected Publications

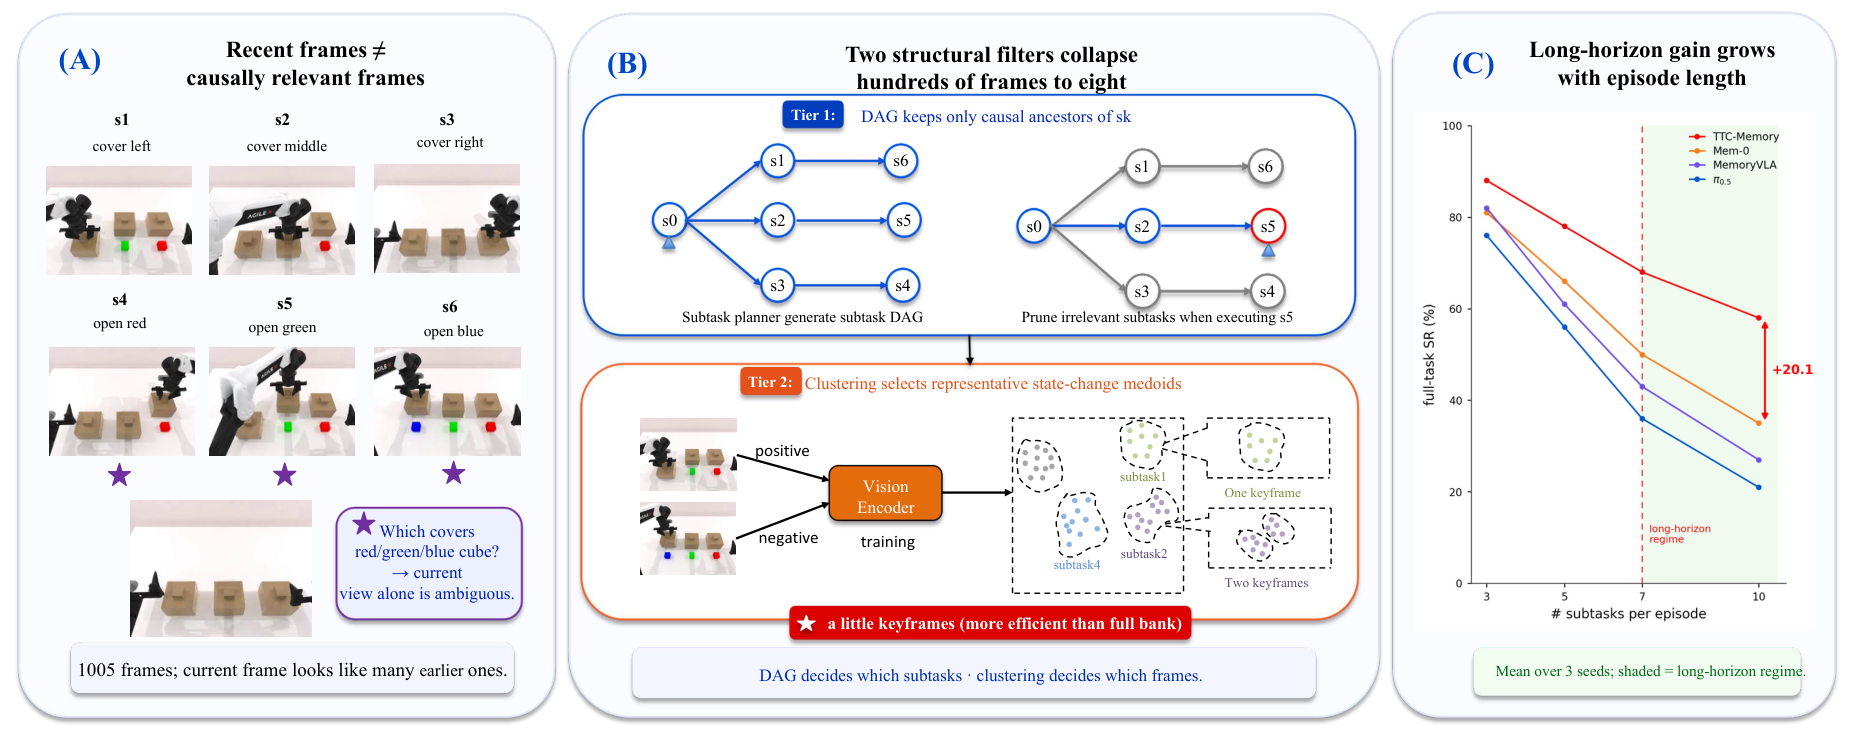
TTC-Memory overview: a subtask dependency graph retrieves causal ancestors, and adaptive clustering selects state-change keyframes

Remembering What Matters: From Markovian to Subtask-Causal Memory in VLA Policies

P. Wang*, F. Bai*, Y. Li*, T. Chou, Y. Xu, Y. Wen, Y. Yang, C. Gao, Z. Zheng, F. Wu

Conference on Neural Information Processing Systems (NeurIPS), 2026

A two-level memory framework for VLA policies that retrieves relevant history through a subtask dependency graph, selects key frames around state changes, and integrates memory into a frozen backbone through graph-aware cross-attention.

* Equal contribution.
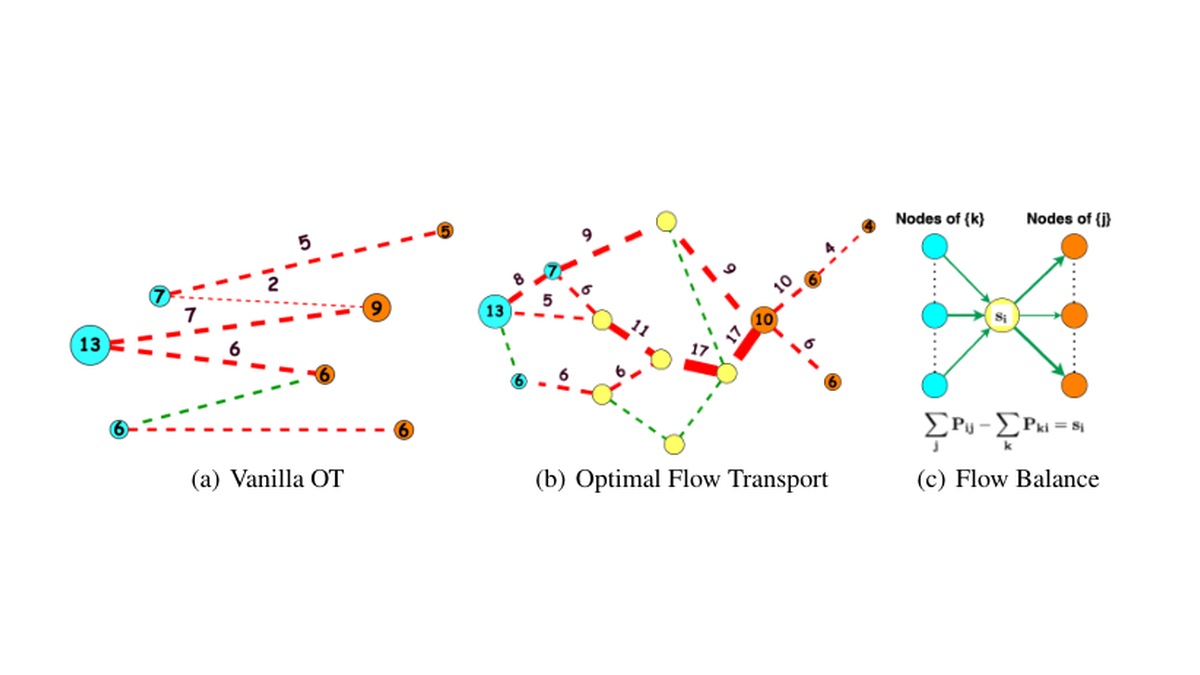
Optimal Flow Transport figure

Optimal Flow Transport and its Entropic Regularization: a GPU-friendly Matrix Iterative Algorithm for Flow Balance Satisfaction

L. Shi, Y. Li, K. Zeng, Y. Tu, J. Yan, et al.

International Conference on Learning Representations (ICLR), 2025

A matrix-iterative optimal transport algorithm for satisfying node and edge flow balance constraints in graph-structured problems.

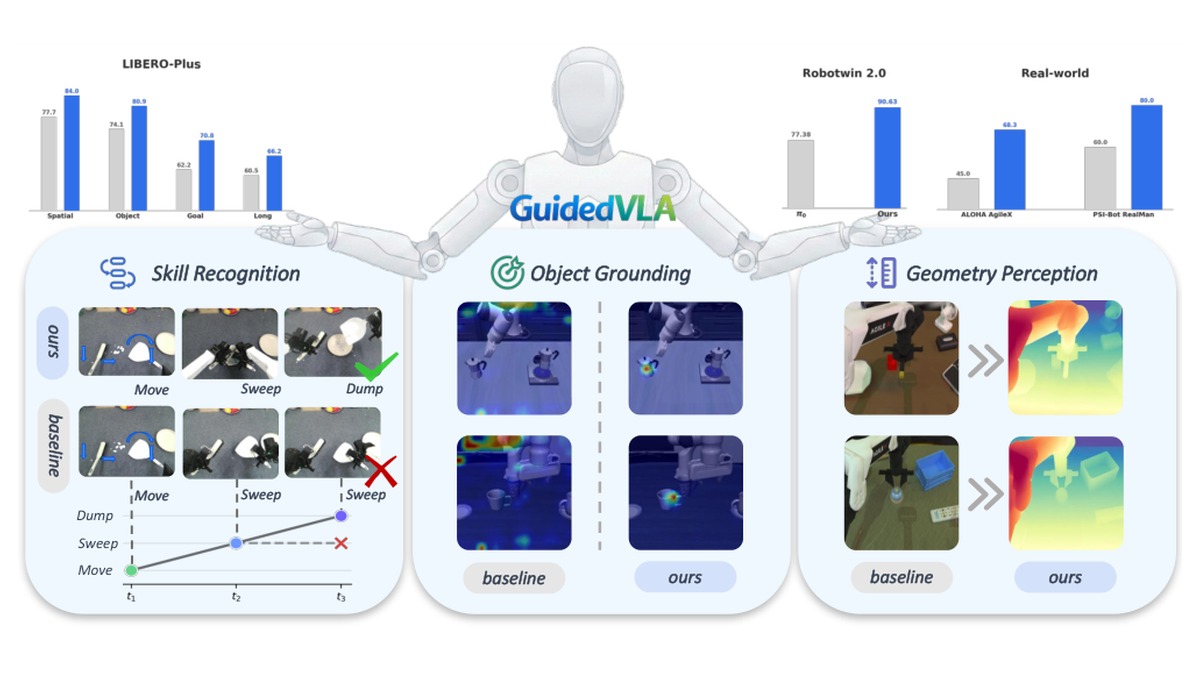
GuidedVLA figure

GuidedVLA: Specifying Task-Relevant Factors via Plug-and-Play Action Attention Specialization

X. Jia, B. Yang, Z. Ge, X. Nie, Y. Zhou, C. Fan, Y. Li, Y. Chai, C. Jing, Z. Liang, Q. Bu, H. Cao, C. Wu, Q. Li, Z. Yang, C. Zhang, H. Li, Z. Wu, J. Yan, Y.-G. Jiang

Robotics: Science and Systems (RSS), 2026

Decouples object pointing, spatial geometry, and timing skill factors by specializing action-decoder attention heads.

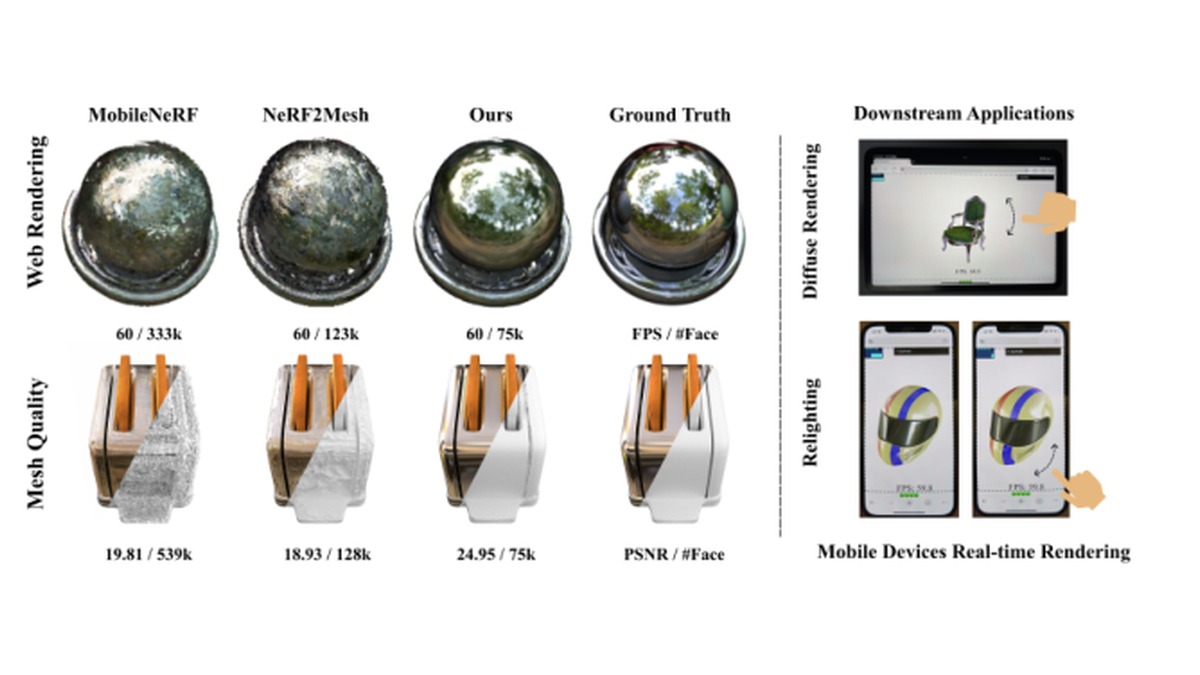
REFRAME rendering comparison figure

REFRAME: Reflective Surface Real-Time Rendering for Mobile Devices

C. Ji, Y. Li, Y. Liao, et al.

European Conference on Computer Vision (ECCV), 2024

Real-time novel-view synthesis pipeline for reflective surfaces on mobile devices.

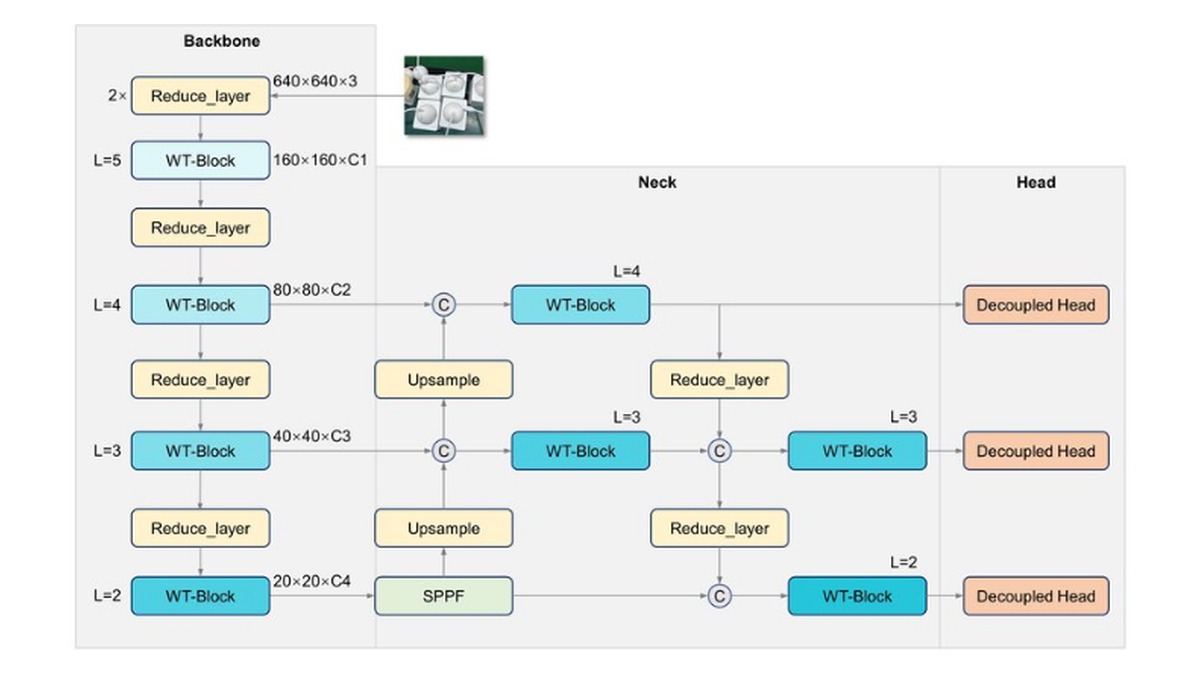
WT-YOLO architecture figure

Efficient Packaging Line Object Counting by Cross-frame Association with Wavelet Convolutions and Trajectory Compensation

L. Wei, Y. Zhu, Y. Li, M. Qian, X. Zuo, B. Chen, S. Liang, Z. Lin, J. Yan, et al.

IEEE Access, 2025

Wavelet-convolution enhanced detection and cross-frame association for packaging line object counting.

Additional Publications & Manuscripts

  • Bench2Dex: A Bimanual Manipulation Benchmark across Dexterous Hands with Simulated Fingertip Visuo-Tactile Support Zhenjie Yang, Yideng Zhang, Dongjie Zhang, Chenyu Jiang, Xianshuai Liu, Yufeng Li, Zuhao Ge, Xingyu Jiao, Zheng Zhang, Kaiyu He, Qifeng Li, He Wang, Yuwen Zhong, Yi Deng, Muyun Jiang, Xianliang Huang, Haisheng Su, Donghang Zhang, Jian Zhang, Xue Yang, Hongyang Li, Xiaosong Jia, Junchi Yan Submitted to ICLR, 2027.
  • Towards Practical Large-scale Dynamical Heterogeneous Graph Embedding: Cold-start Resilient Recommendation M. Long, J. Liu, Y. Li, H. Xiong, J. Yan, K. Wang, Y. Cao, J. Ding IEEE Transactions on Knowledge and Data Engineering (TKDE), 2025.
  • GEARS: Seeing Geometry, Diffusing Actions for Zero-Shot Sim-to-Real Dexterous Manipulation F. Bai, T. Chou, Y. Li, Y. Li, Y. Wang, Y. Mao, H. Zhang, Y. Wang, R. Zhu, Y. Wen, Y. Yang, Y. Chen, et al. Submitted to ICLR, 2027.
  • SafeTransport: A Unified Capacity-Flow View of Safe Reinforcement Learning Y. Li, F. Bai, T. Chou, Q. Li, J. Gao, J. Yan Submitted to ICLR, 2027.
  • Rsync: Reward-Manifold Driven Adaptive Synchronization for Sample-Efficient Real-World Reinforcement Learning Y. Cai, F. Bai, T. Yu, Y. Pu, Y. Mao, Y. Wang, T. Chou, Y. Li, Y. Li, Y. Yang, H. Zhang, M. Li, Y. Chen, et al. Submitted to ICLR, 2026.
  • Beyond Polarity Counting: A Polarity-Entropy Framework for Label-Free Neural SAT Phase Guidance Y. Li*, X. Zheng*, J. Yan Submitted to IEEE Transactions on Pattern Analysis and Machine Intelligence (TPAMI).

Experience


Education and Honors


Selected Projects

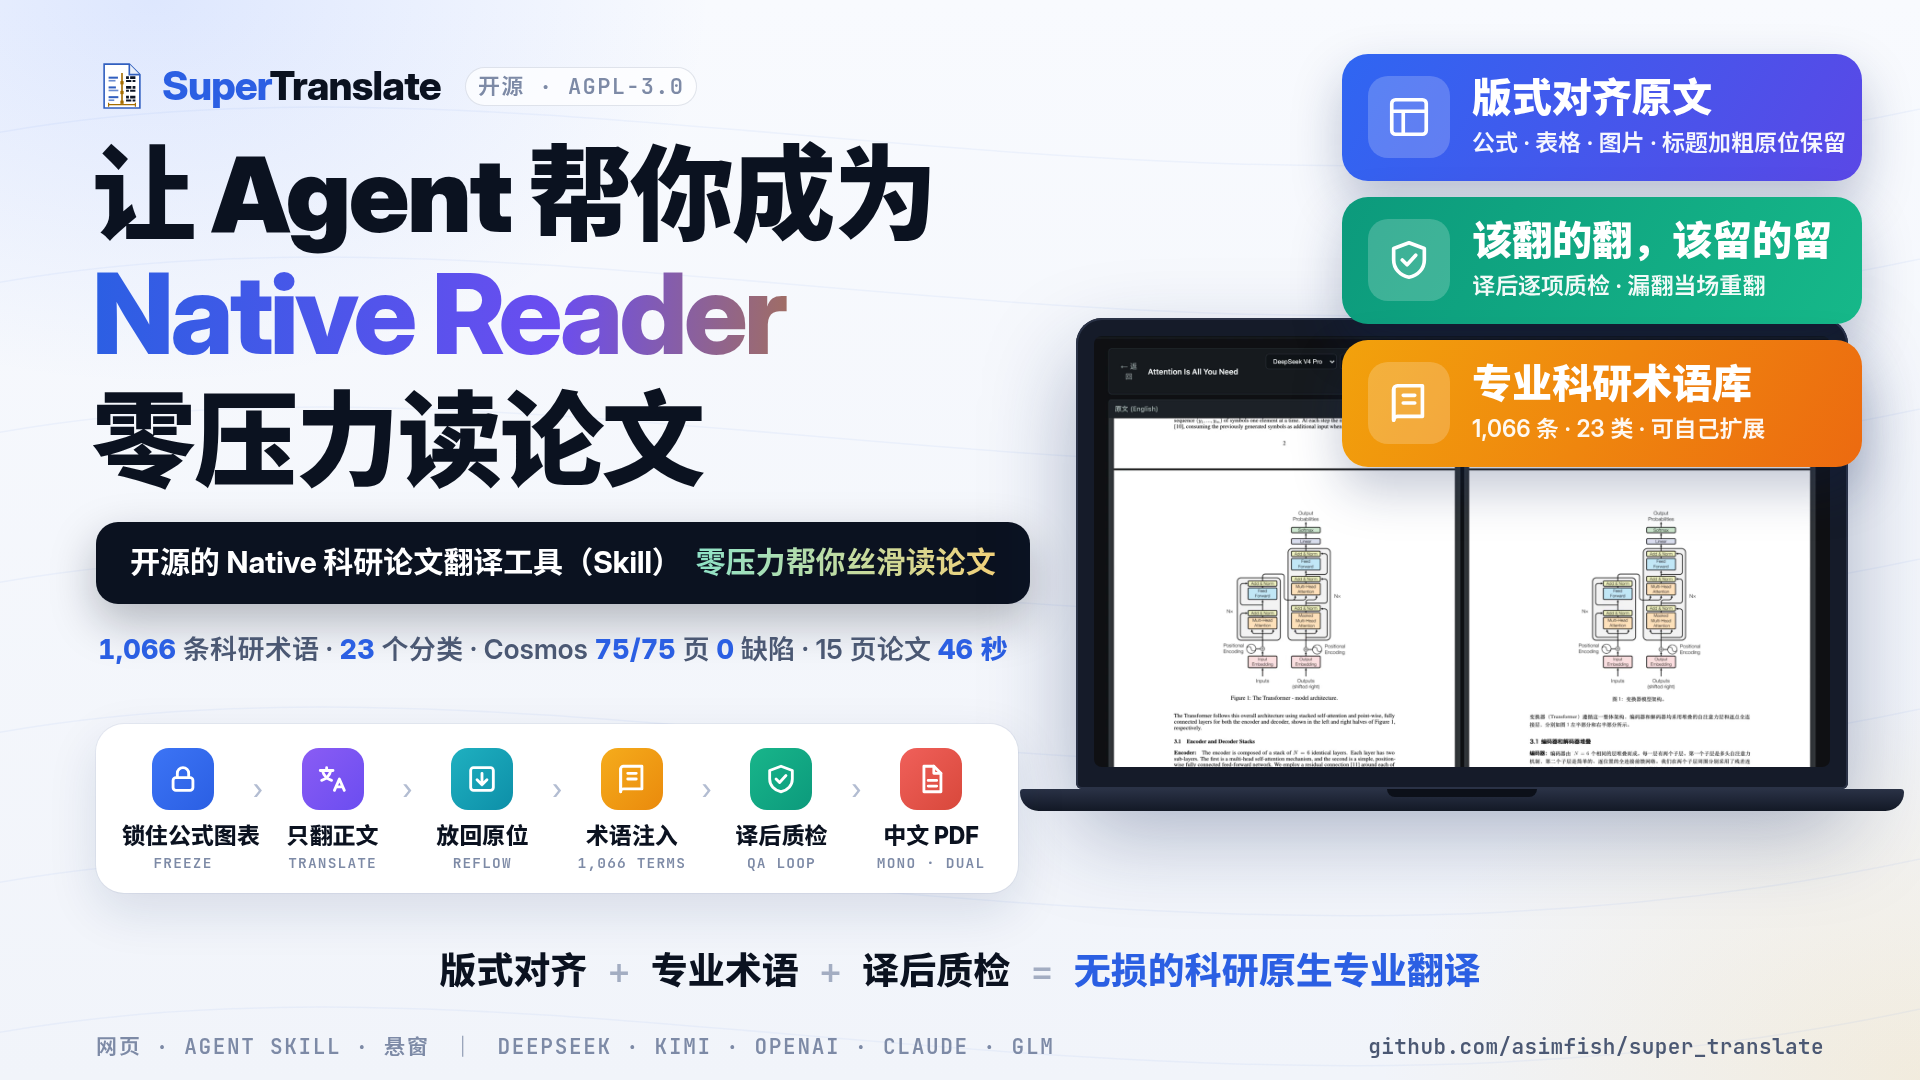
SuperTranslate: Let your Agent help you become a Native Reader
Native Reader · Open-source research tool

SuperTranslate

Let your Agent help you become a Native Reader.

Read papers with less friction. An open-source research PDF translator that preserves the original page layout, protects formulas and figures, and translates prose with research terminology libraries and post-translation quality checks. Available through Web, Agent Skill, a native macOS floating window, and Zotero.

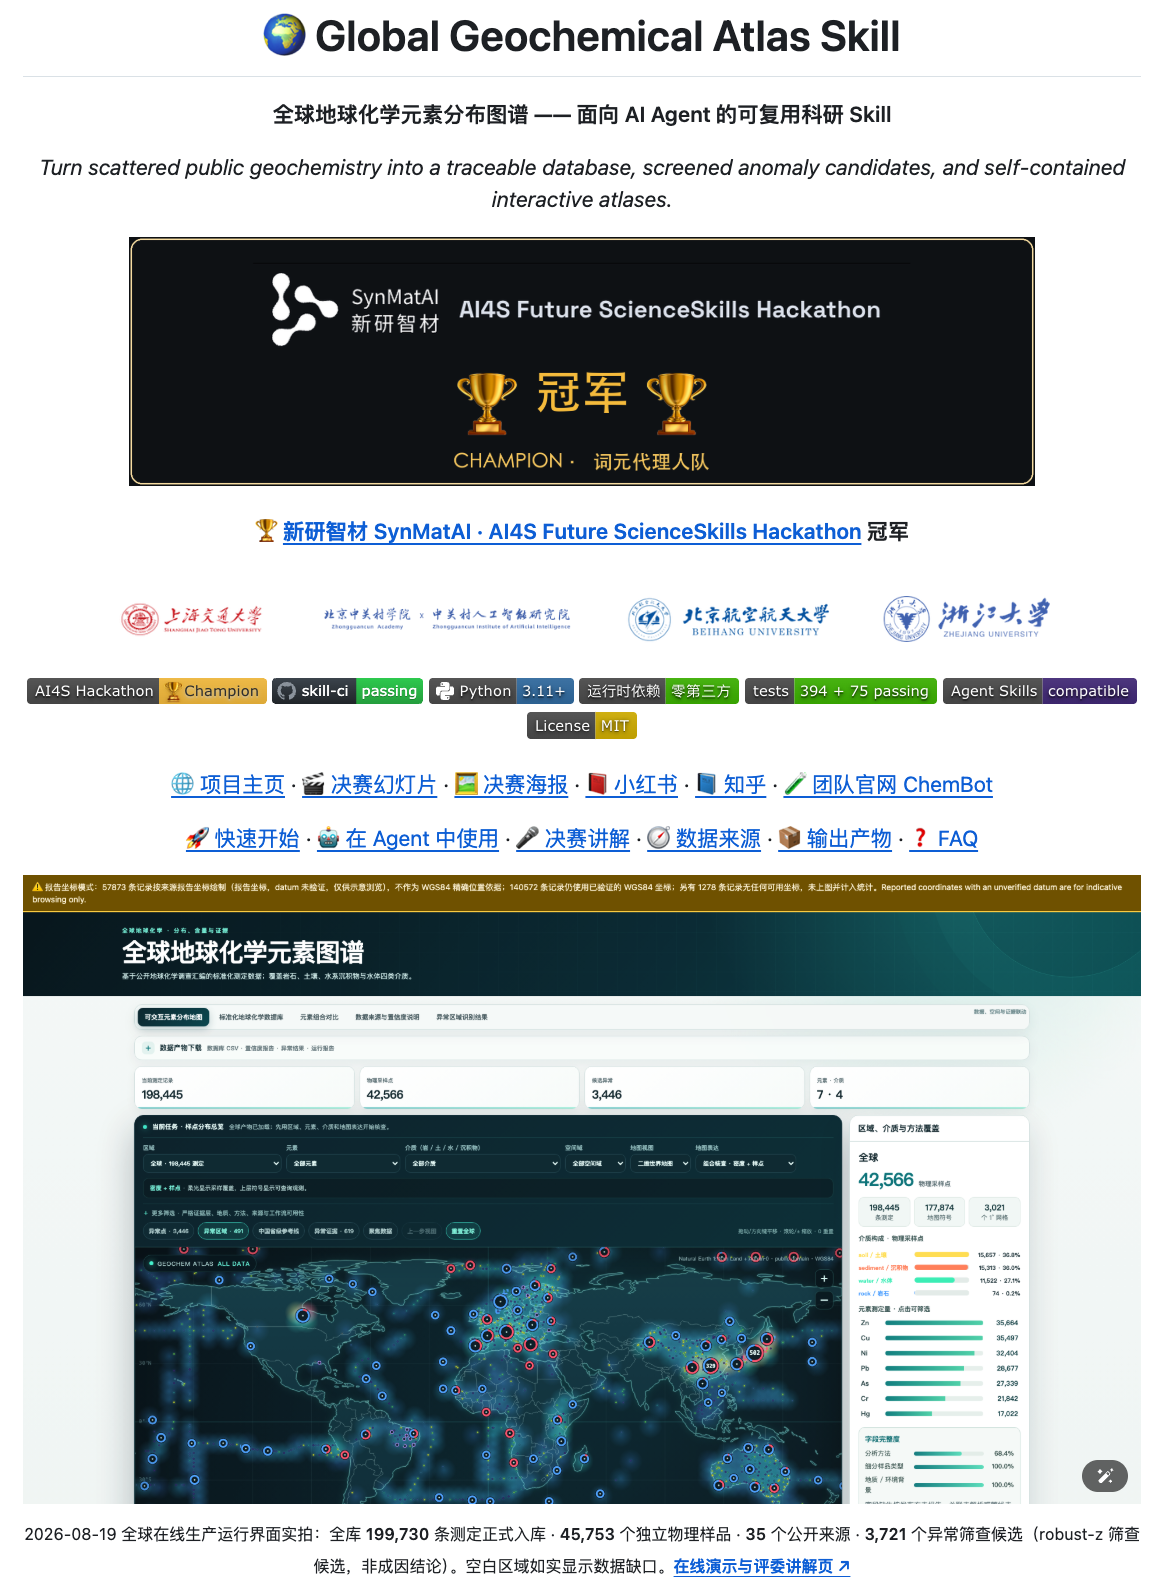
Global Geochemical Atlas Skill project overview and hackathon champion announcement
Hackathon Champion | Agentic Science Skill

Global Geochemical Atlas Skill

One prompt turns a research question into a trustworthy, traceable, and interactive atlas of the temporal evolution of global geochemical element distributions.

Global Geochemical Atlas Skill translates heterogeneous requests from researchers into one unified, Agentic-Native workflow for trustworthy, interactive, traceable, and time-aware geochemical research.

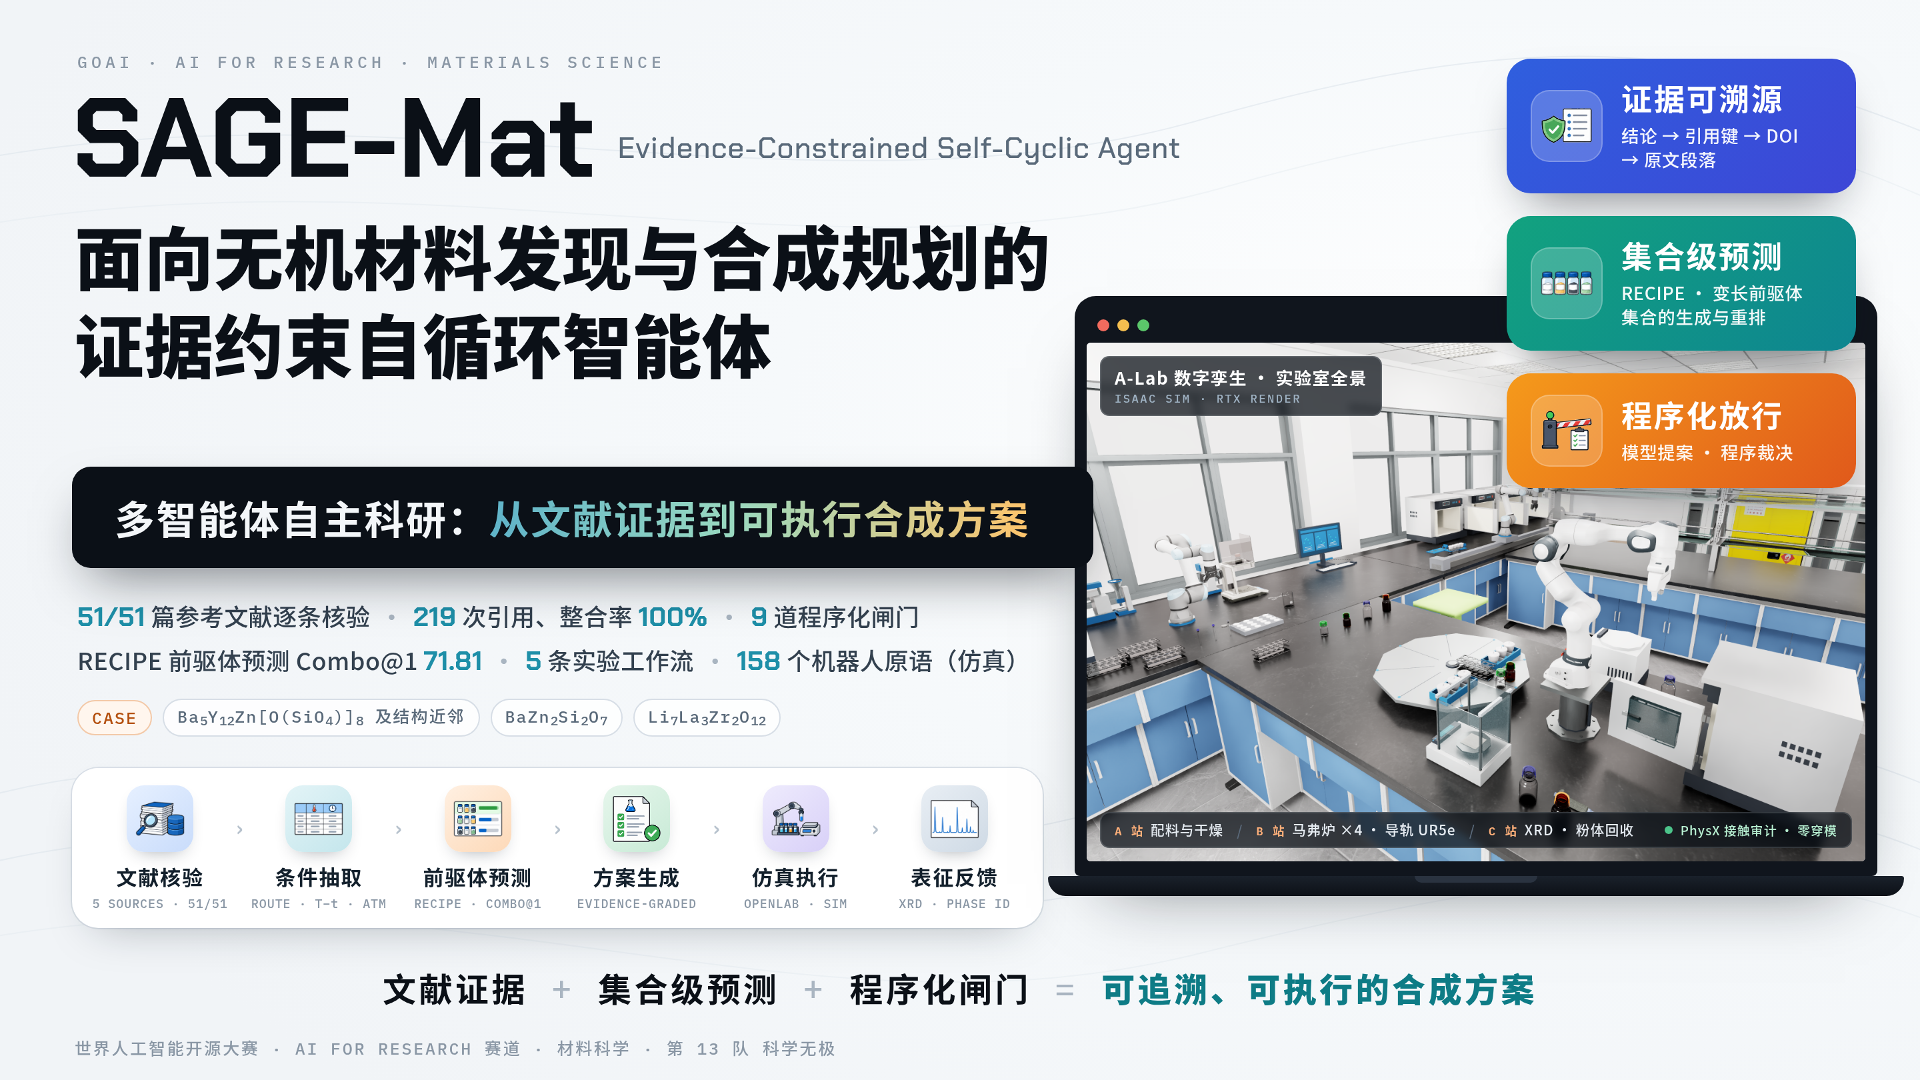
SAGE-Mat evidence-constrained self-cyclic agent for inorganic materials discovery and synthesis planning
GOAI | World AI Open Source Competition

SAGE-Mat

An evidence-constrained self-cyclic agent for inorganic materials discovery and synthesis planning.

SAGE-Mat closes the loop from literature evidence and citation tracing to synthesis plan prediction and embodied simulation. I built the Isaac Lab laboratory simulator and the robot-operation pipeline for full-process synthesis experiments.

Local-first AI workflow system

ShrimpFlow

A programmer workflow system that observes terminal, git, and AI-agent interaction traces, models a developer's workflow and cognitive preferences, and exports executable behavior specifications such as ClawProfile / CLAUDE.md for personalized AI coding agents.

  • Shadow layer: terminal, git, agent-session, and environment event collection.
  • Brain layer: workflow, preference, decision, and temporal pattern modeling.
  • Autopilot layer: portable behavior specs for downstream coding agents.

Global Reach

Visitors Worldwide

Approximate visitor locations and total pageviews.

Locations are approximate; no precise personal location is displayed. Visitor statistics